Ph.D. Candidate · Tsinghua University
Keyu Chen (陈可禹)
Traffic Simulation · RL Post-Training · Autonomous Driving
I am a third-year Ph.D. student in the School of Vehicle and Mobility at Tsinghua University, advised by Prof. Sifa Zheng.
My research focuses on reinforcement learning (RL) post-training for autonomous driving, with broader interests in Physical AI. I am particularly interested in how RL and closed-loop interaction can improve the adaptability, robustness, and generalization of intelligent agents in complex physical environments.
Academic background
Education

Tsinghua University
Ph.D. candidate in Mechanical Engineering, School of Vehicle and Mobility
Beijing, China
Nanjing University of Aeronautics and Astronautics
B.Eng. in Vehicle Engineering
Nanjing, ChinaRecent updates
News
CRAFT was accepted to NeurIPS 2026.
Released CRAFT. The project page is now live.
ForSim was accepted to ICRA 2026.
Released RIFT. The project page is now live.
FREA was accepted to CoRL 2024 as an Oral presentation (4.3%).
IGT was accepted to Knowledge-Based Systems.
Research output
Publications
Selected Publications
Representative work
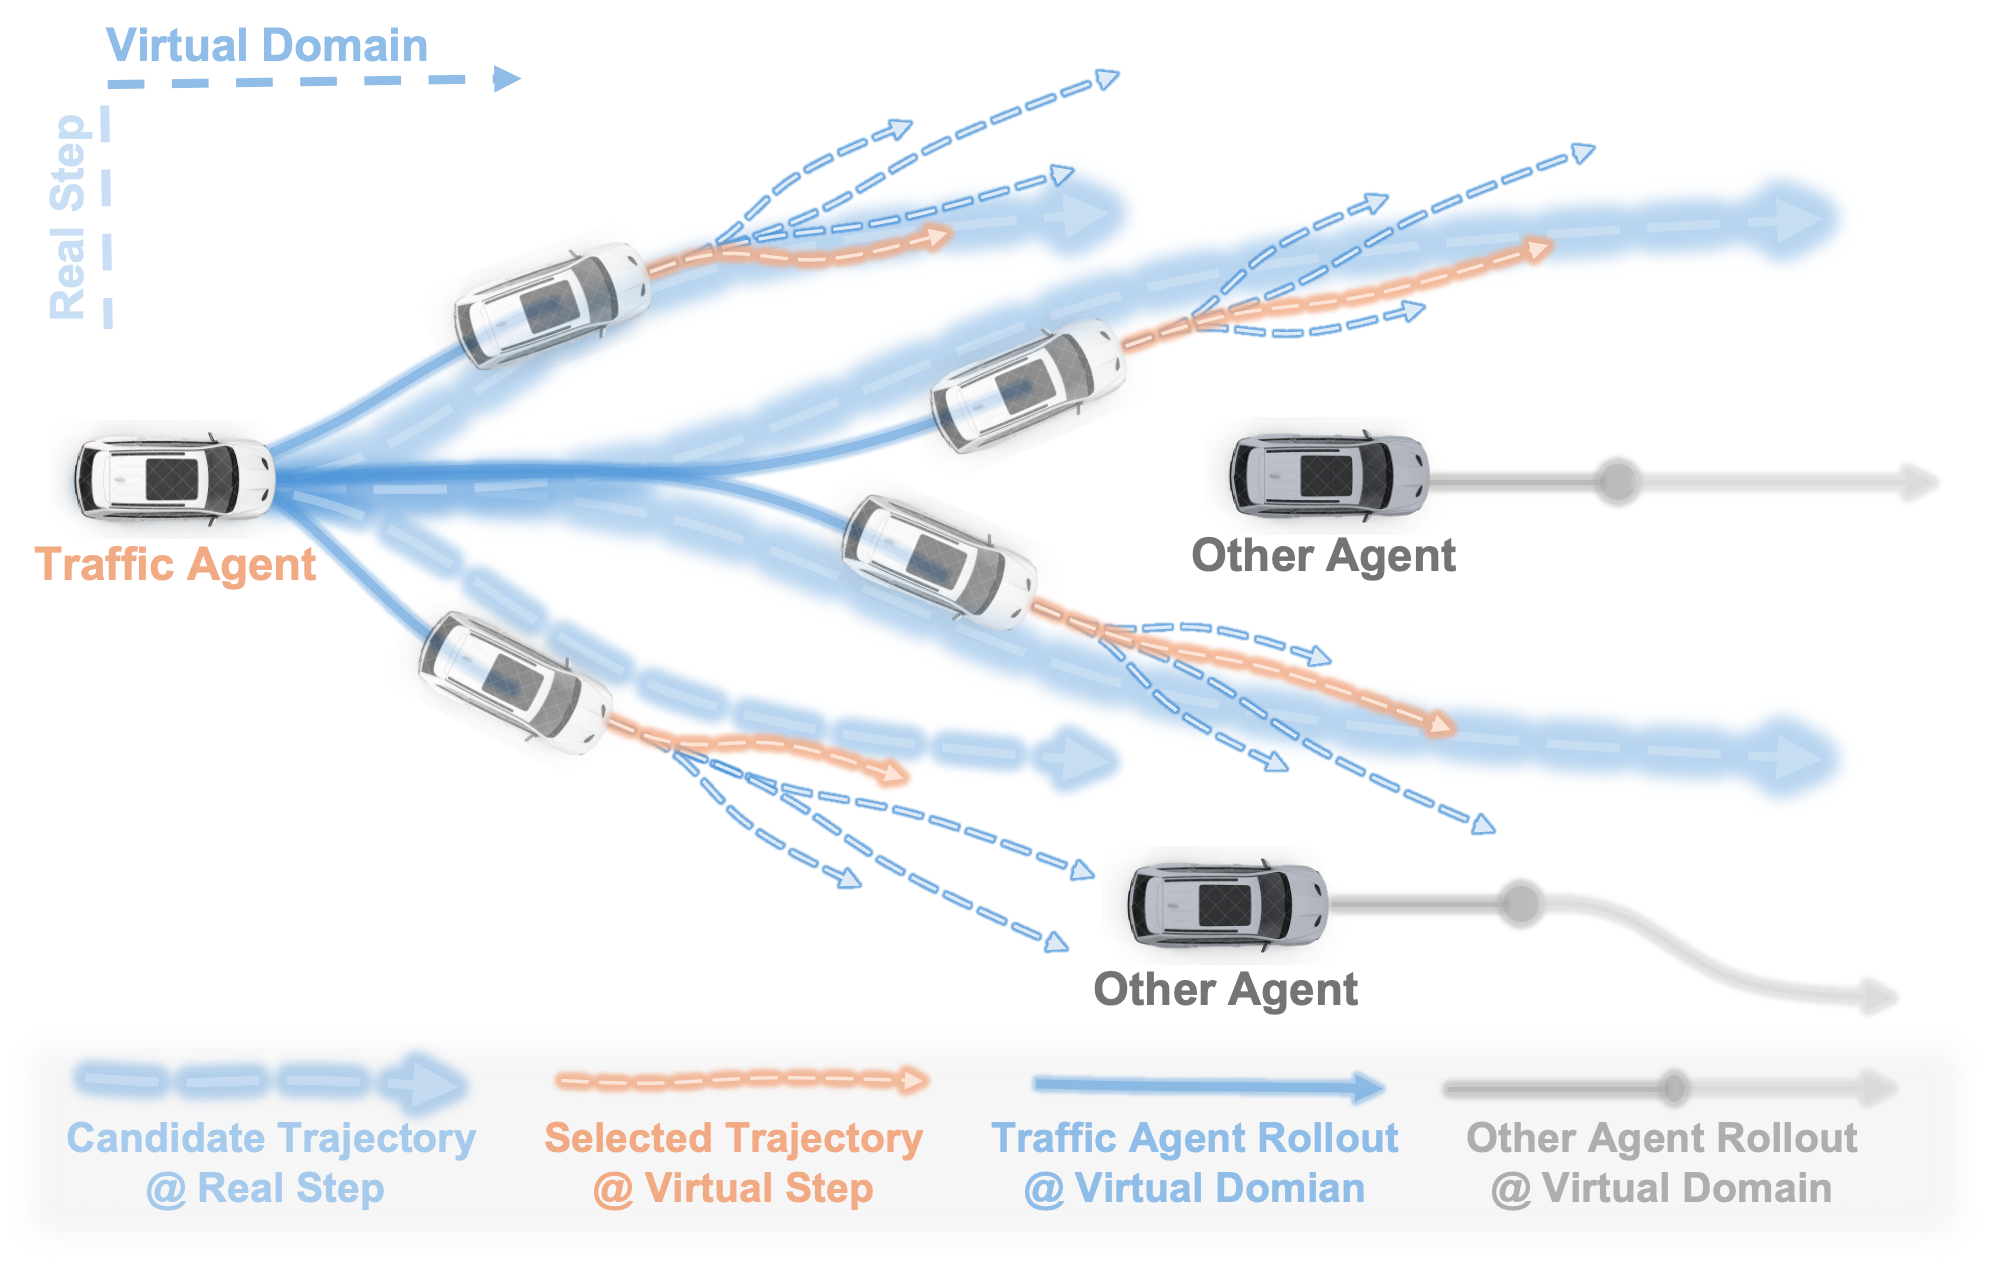
ForSim: Stepwise Forward Simulation for Traffic Policy Fine-Tuning
ForSim achieves high-fidelity traffic simulation through stepwise closed-loop trajectory propagation, combining physical dynamics for multimodal diversity with interaction-aware agent updates for realistic behavioral consistency.
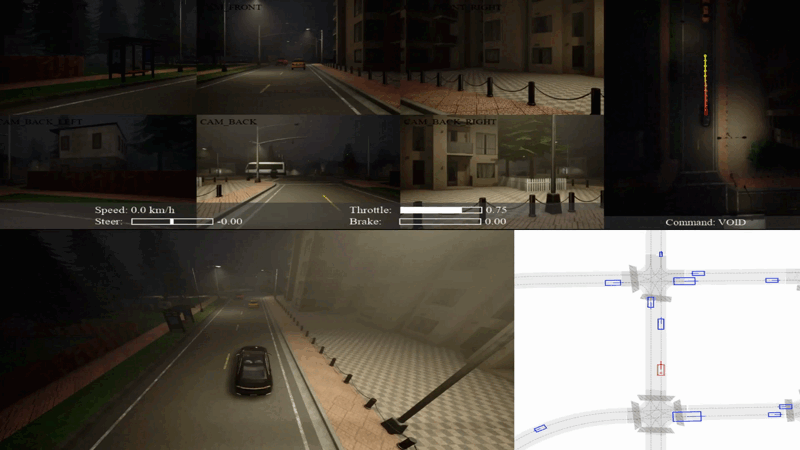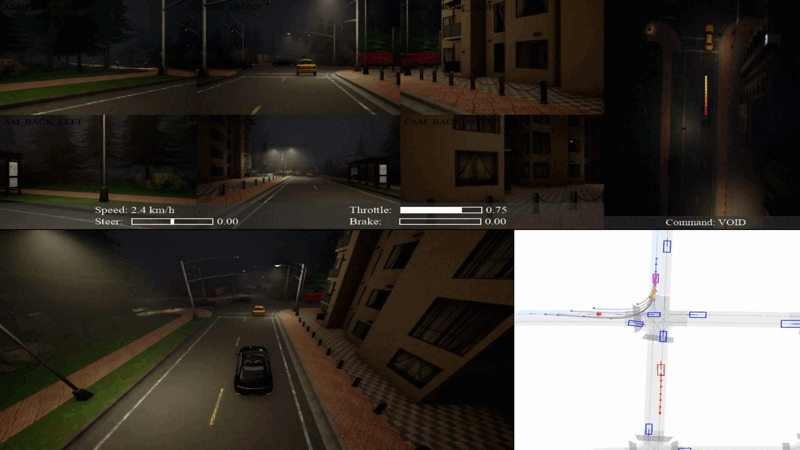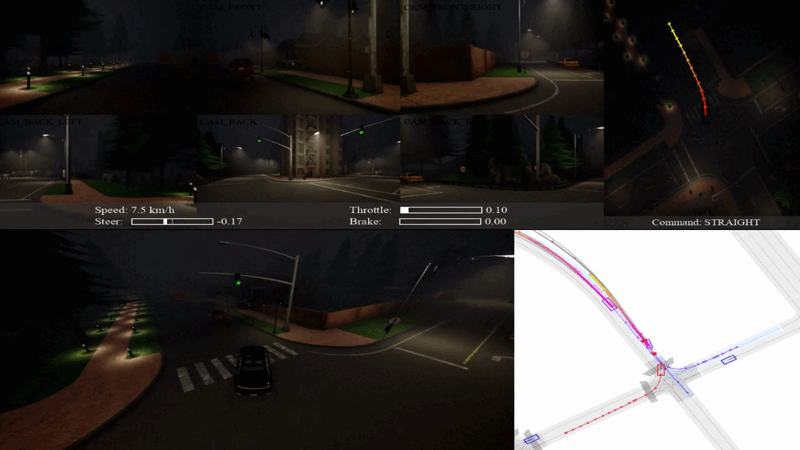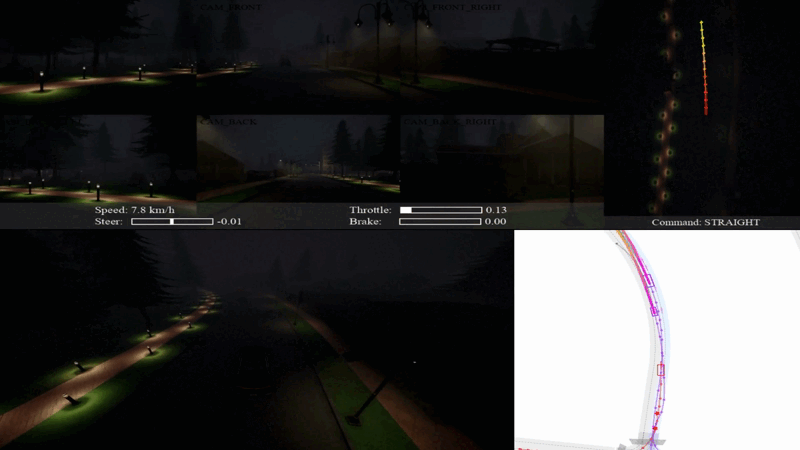
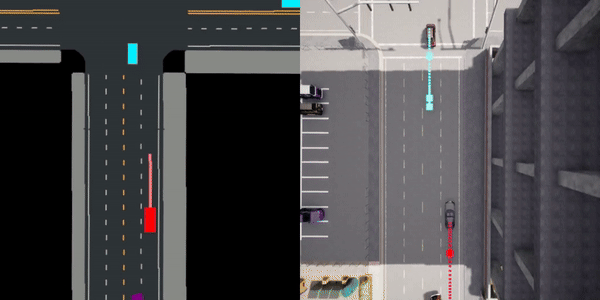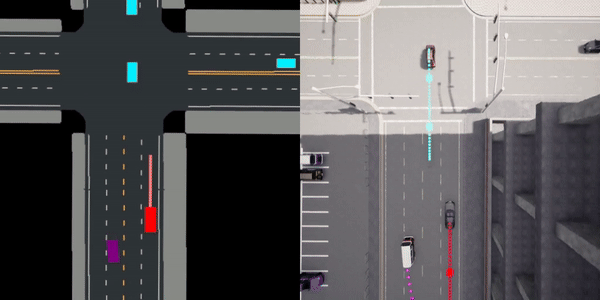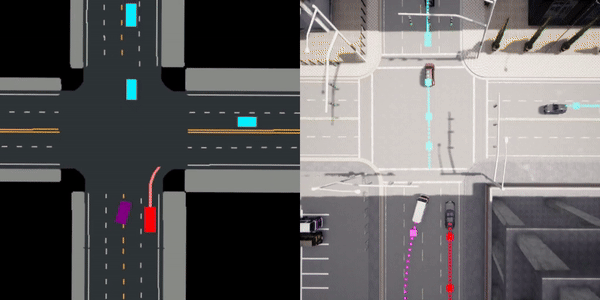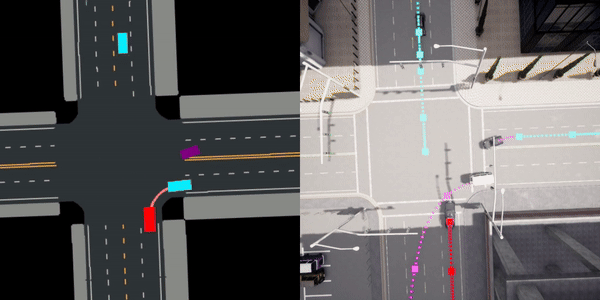
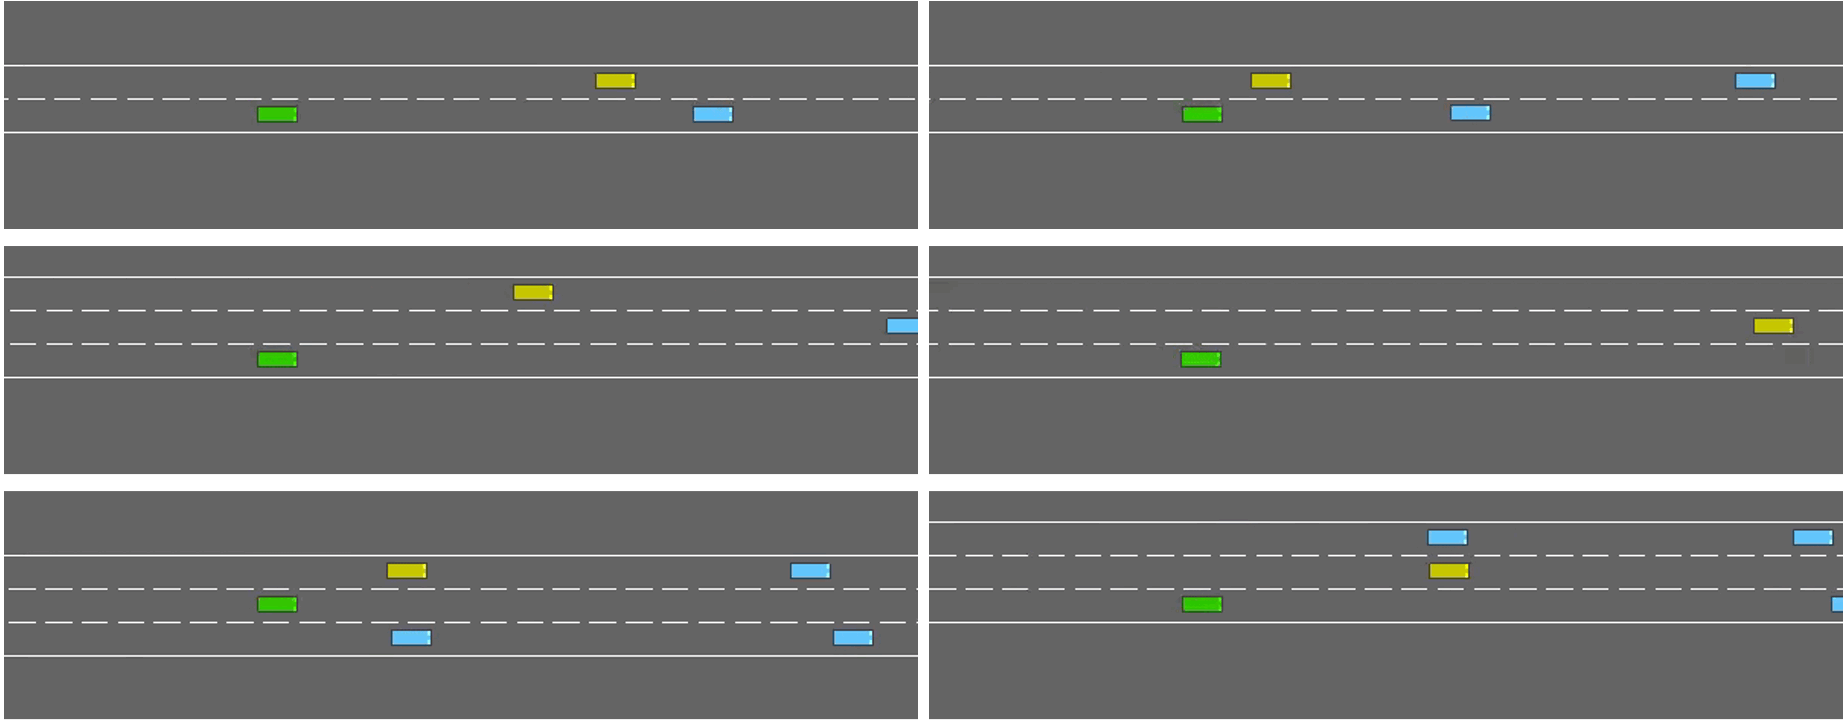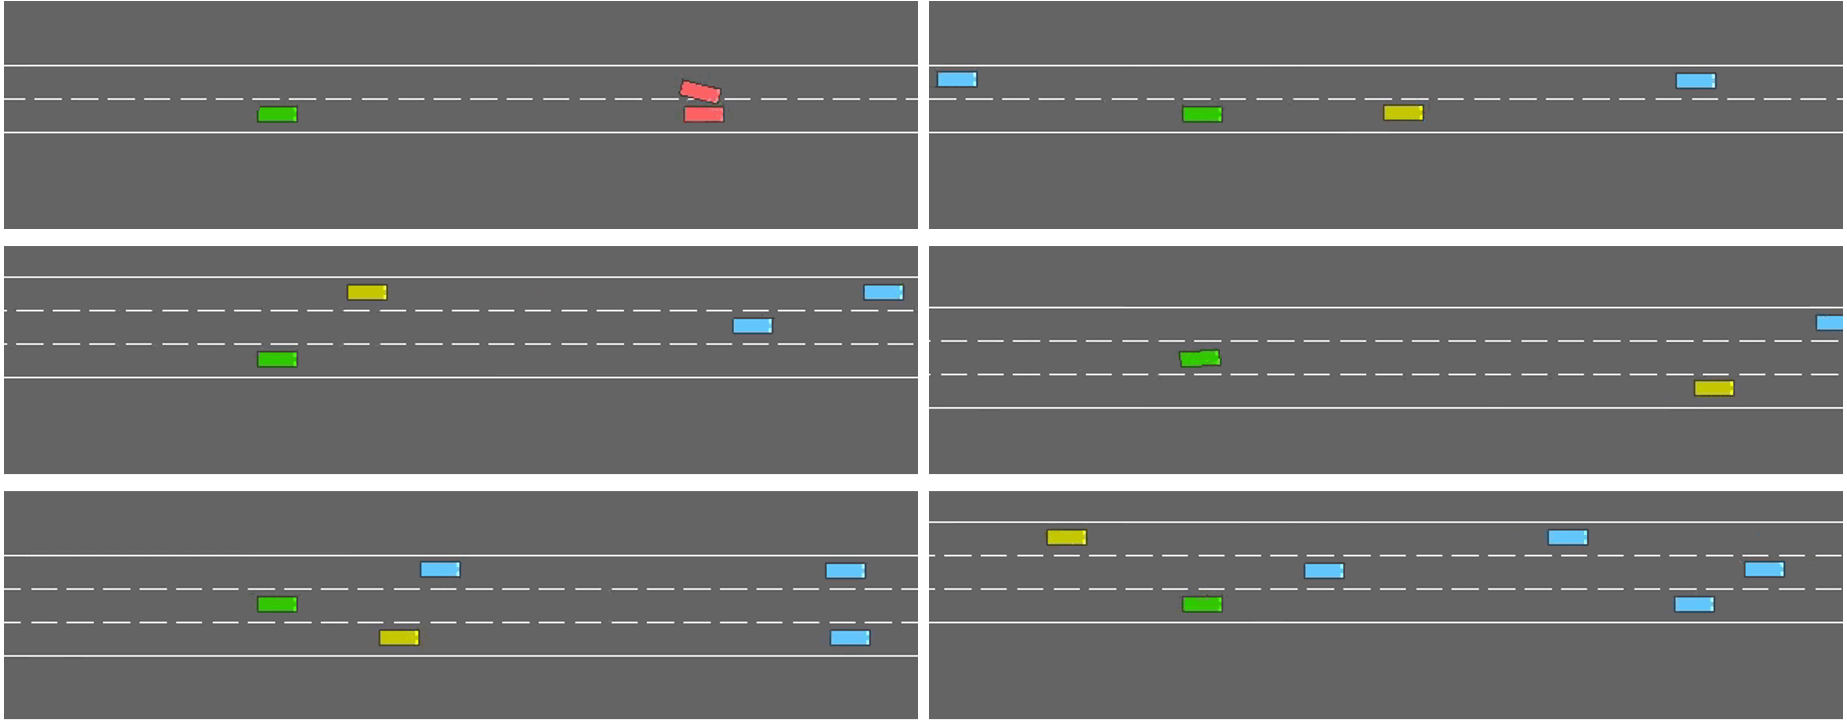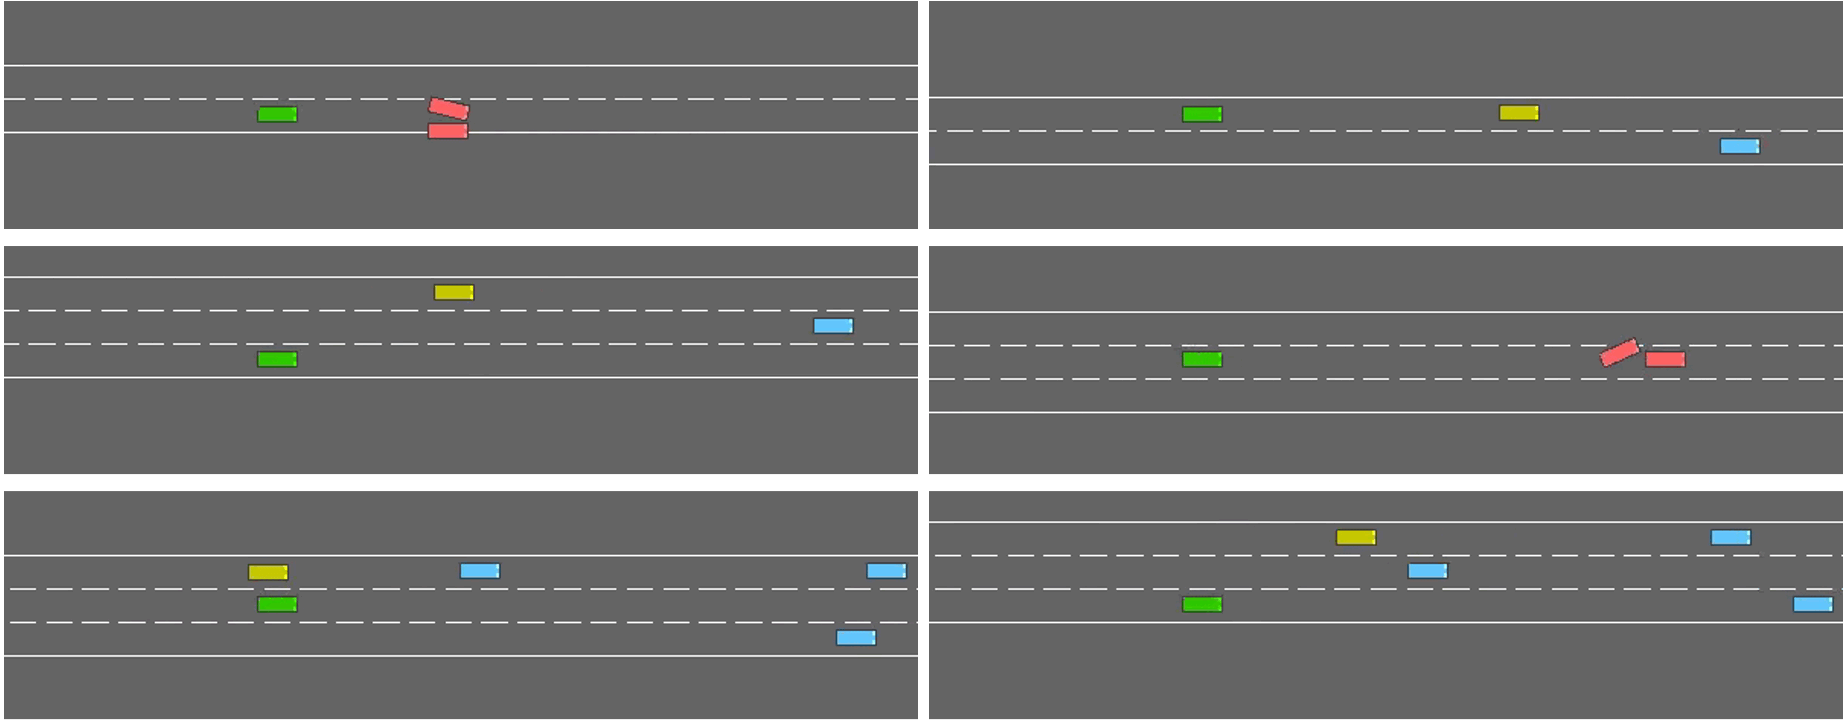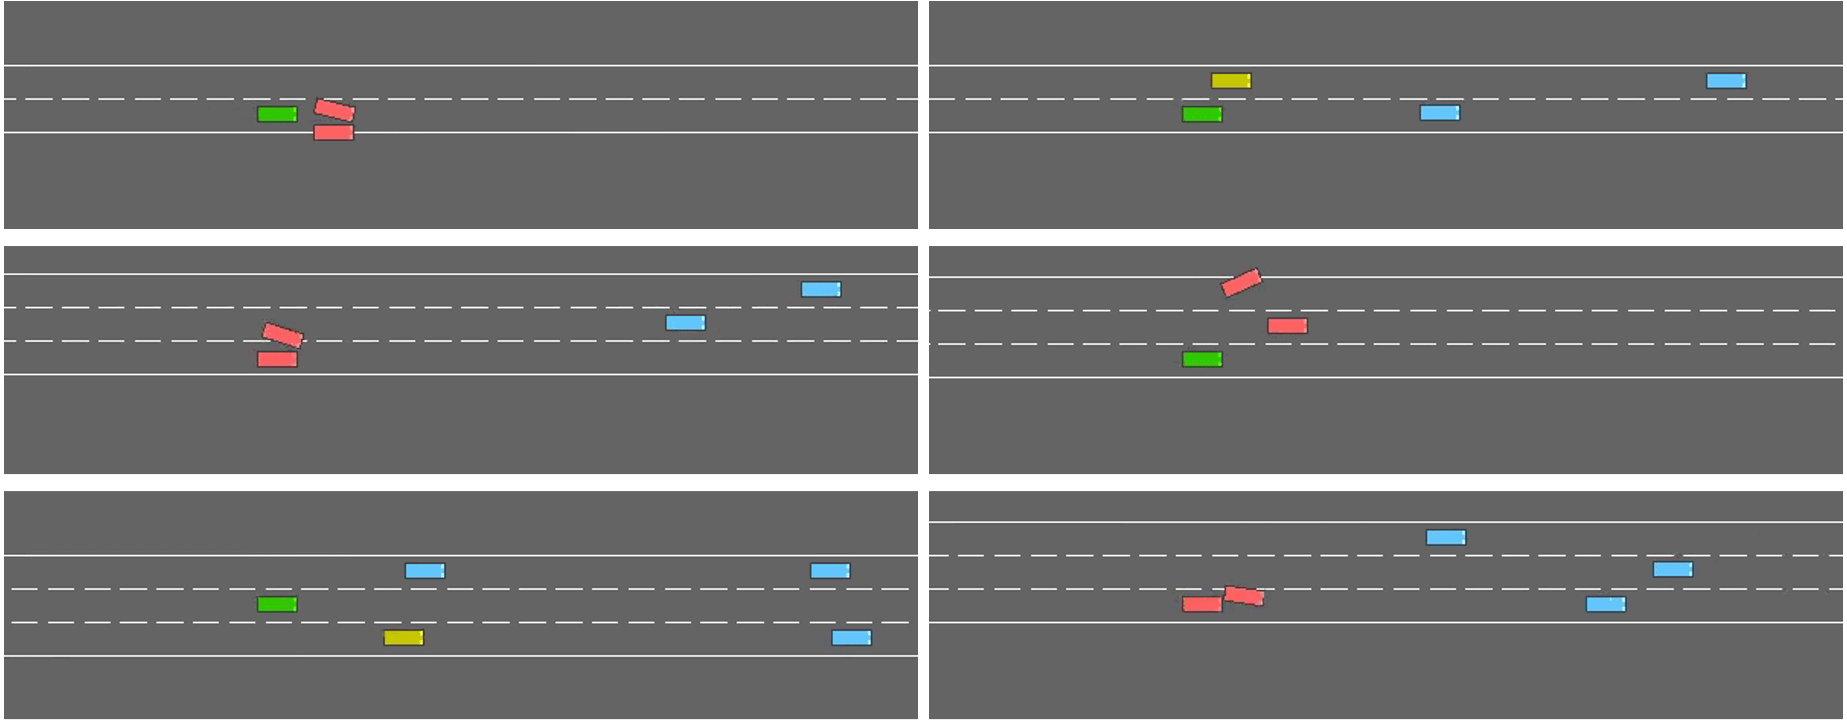
RIFT: Group-Relative RL Fine-Tuning for Realistic and Controllable Traffic Simulation
RIFT achieves realistic and controllable traffic simulation by combining imitation-learning pre-training in a data-driven simulator with reinforcement-learning fine-tuning in a physics-based simulator.
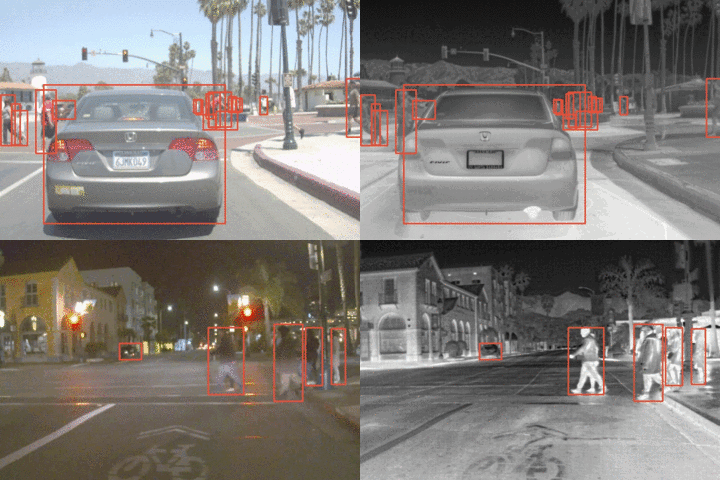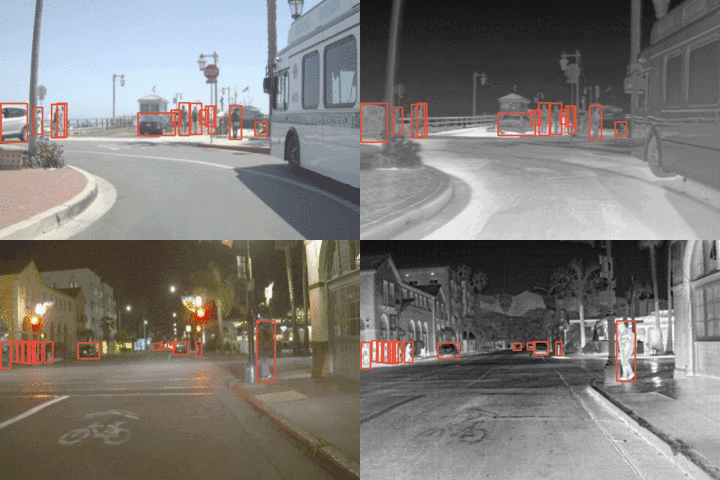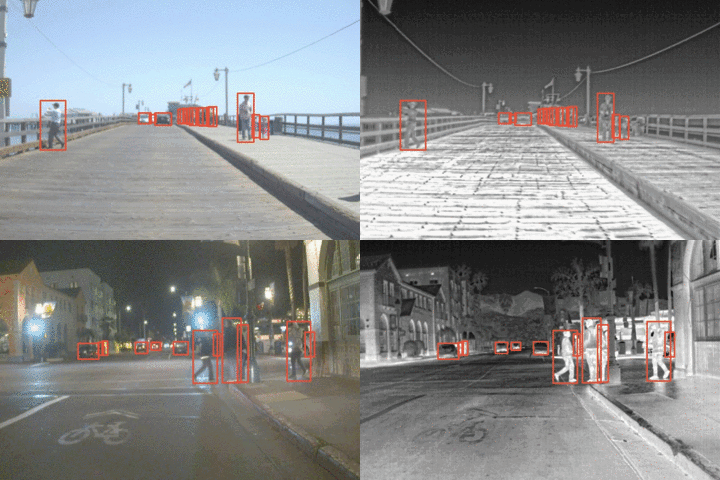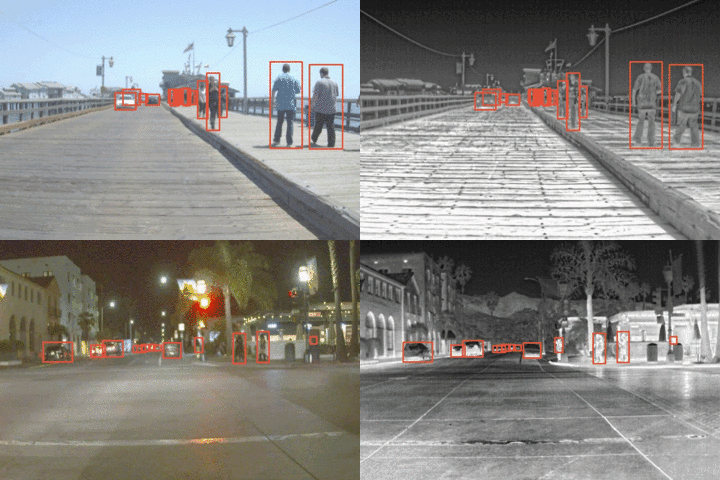
IGT: Illumination-Guided RGB-T Object Detection with Transformers
IGT uses illumination intensity to guide multimodal feature fusion, enabling the comprehensive use of complementary cross-modal information in object detection.
All Publications
Additional collaborative work


Open source
Projects
Industry and research
Internships


Tsinghua Automotive Research Institute (Suzhou)
Safety-critical scenario generation for autonomous driving
Suzhou, China
Recognition
Honors & Awards
Outstanding Graduate Top 1%
Nanjing University of Aeronautics and Astronautics
Outstanding Bachelor Thesis Award Top 5%
Nanjing University of Aeronautics and Astronautics
National Scholarship Top 1%
Nanjing University of Aeronautics and Astronautics